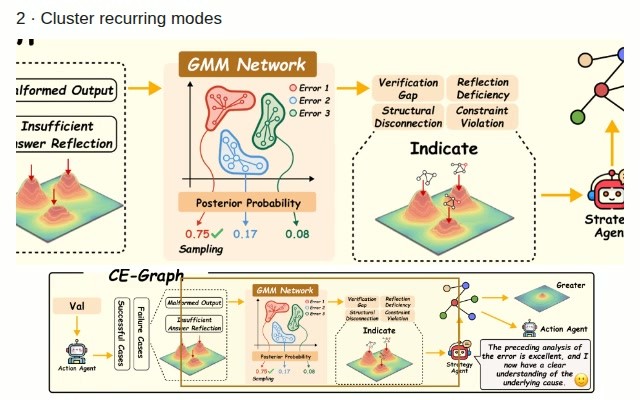
Can LLMs Debug Robots by Editing Their Weights?
An LLM edited 65 token-embedding rows in a pretrained robot policy. Explore the paired rollouts and replay the complete editing session.
Same instruction. Different outcome.
“activate the cooking appliances heat source”
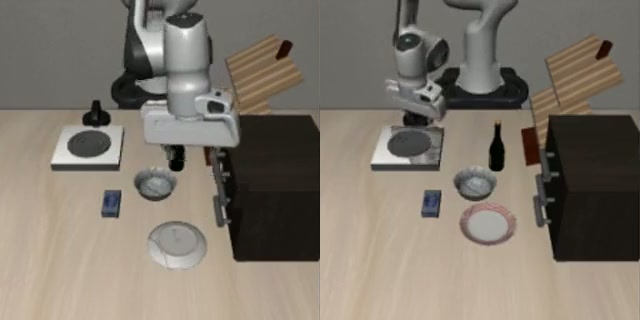
Timed out · 300 stepsSuccess · 78 steps
Selected held-out example · LIBERO simulation